TurboPi vs ClawPi: Which Raspberry Pi ROS2 Robot Car Should You Choose?
Quick Answer
- Choose TurboPi if you want to focus on AI vision interaction applications and are looking for a beginner-friendly platform to learn ROS2 and visual algorithms.
- Choose ClawPi if you prefer a more convenient LCD screen interaction experience, while still learning core ROS2 functions and exploring SLAM mapping, navigation, and embodied AI applications.
1. Introduction
Raspberry Pi ROS2 robot cars are a popular starting point for beginners learning robot programming, AI vision, and intelligent applications. Different models emphasize different technical strengths: some go deep into AI vision algorithms, while others integrate higher-end hardware such as LiDAR to support more advanced ROS2 features (such as SLAM mapping). Clearly defining your core needs is the key to choosing the most suitable platform.
2. Product Overview
Both TurboPi and ClawPi from Hiwonder are built on the Raspberry Pi ROS2 platform. They share core capabilities such as omnidirectional movement, AI vision recognition, robotic arm grasping, and multimodal large model interaction. However, their hardware configurations and teaching focus are clearly differentiated.
2.1 TurboPi: A Systematic AI Vision Learning Robot Car
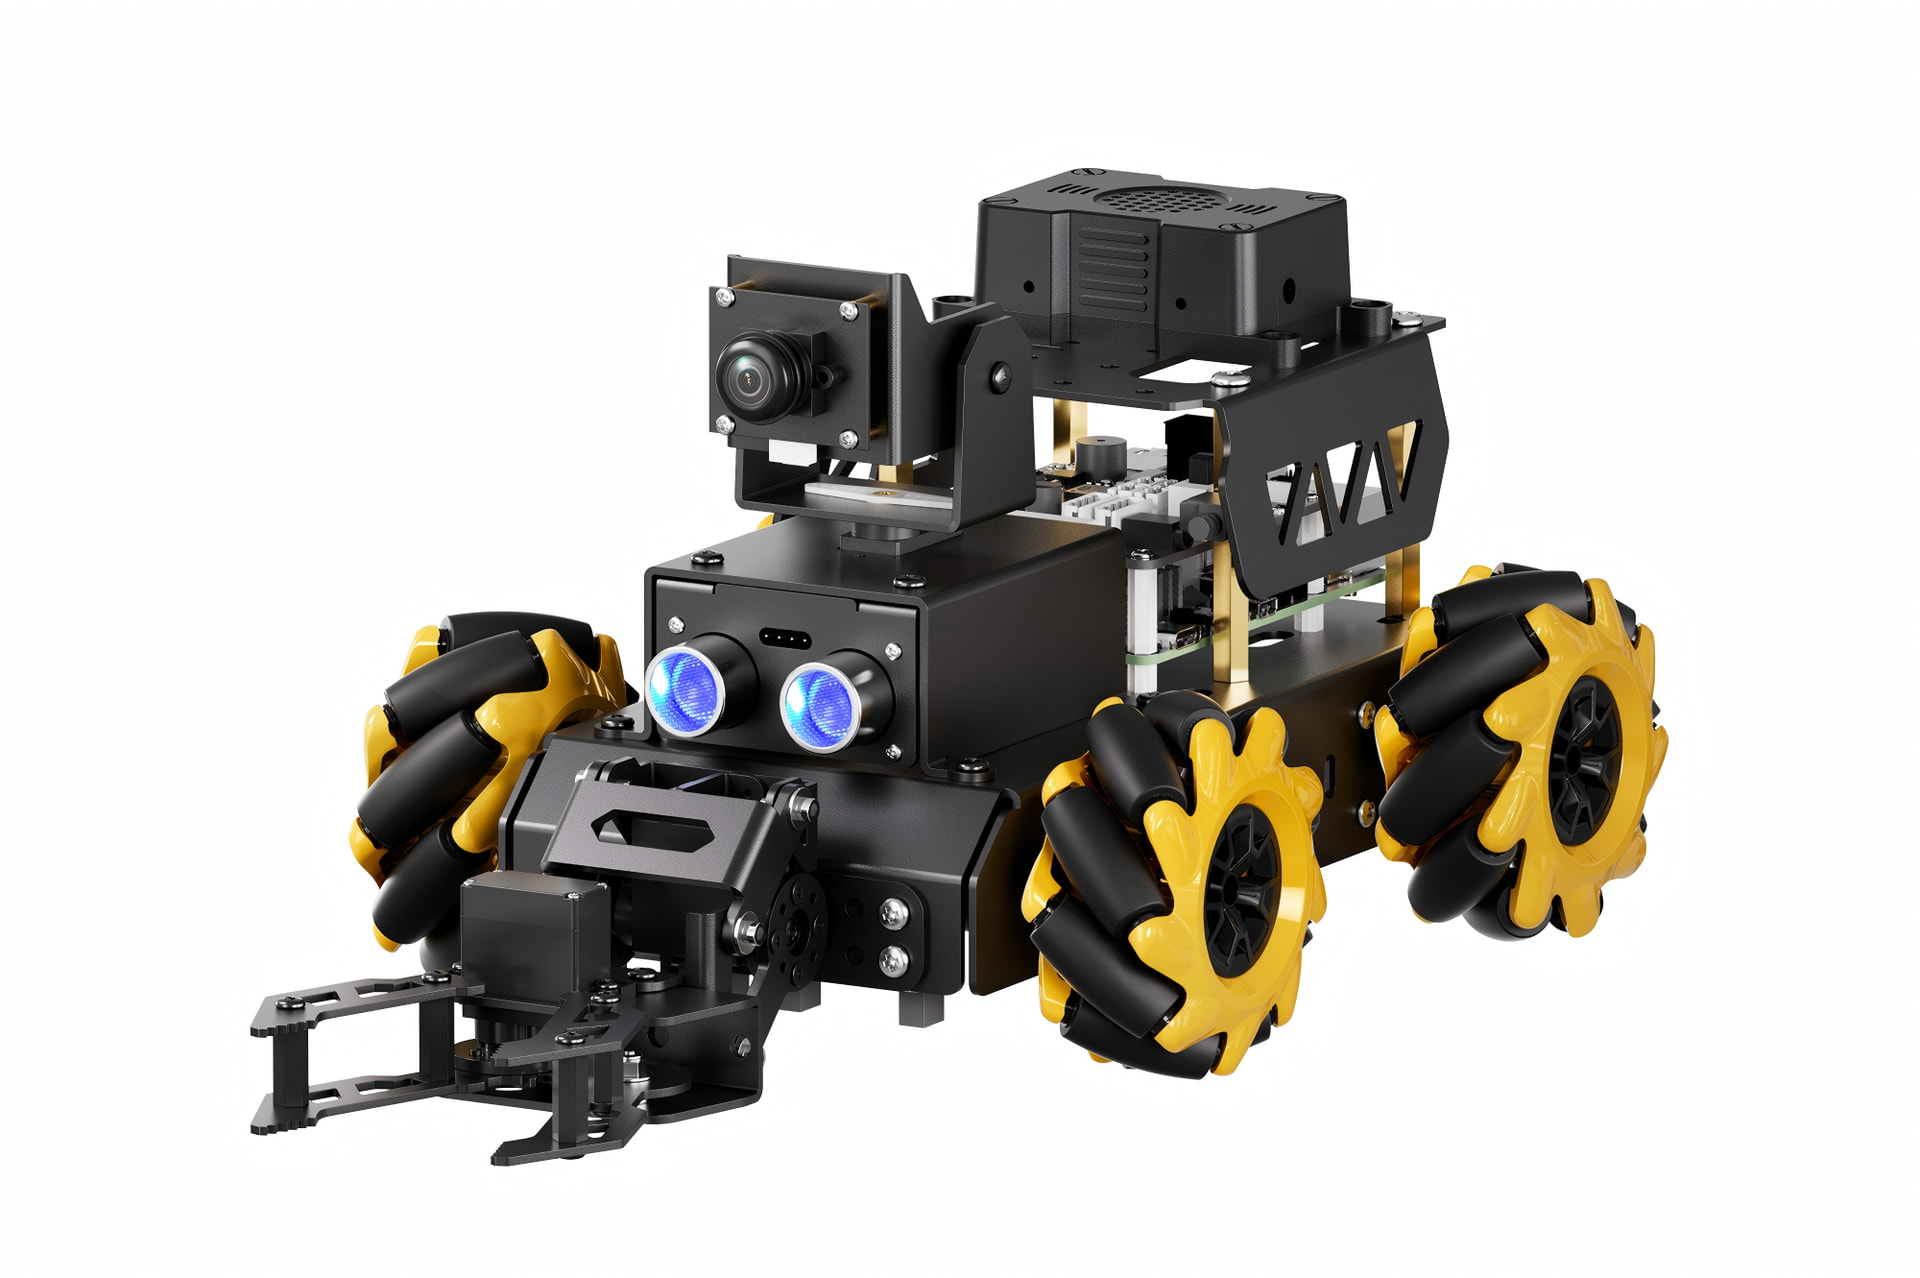
Positioning: Focuses on AI vision algorithms and serves as an ideal starting point for robot programming learning.
Hardware Configuration: Powered by Raspberry Pi 4B/5, equipped with a Mecanum wheel chassis, high-performance DC motors, a 2-DOF pan-tilt camera, a 2-DOF robotic arm, and the WonderEcho Pro AI voice interaction module.
Core Advantage: Comes with a highly complete curriculum. It progresses systematically from Python basics and OpenCV vision algorithms to embodied AI applications, making it ideal for beginners who want to build a complete AI vision learning path.
2.2 ClawPi: A Cost-Effective ROS2 Embodied AI Entry Platform
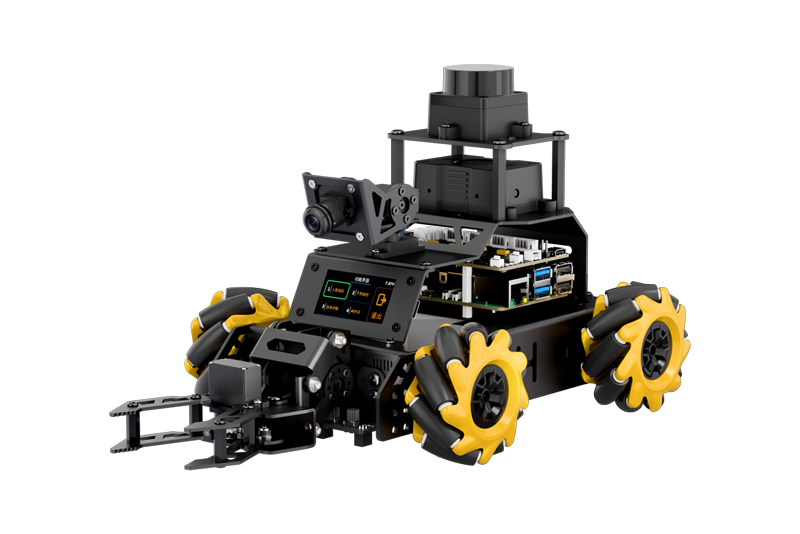
Positioning: A low-barrier, high-value ROS2 embodied AI entry platform.
Hardware Configuration: Powered by Raspberry Pi 5. In addition to the 2-DOF pan-tilt camera, 2-DOF robotic arm, and AI voice interaction box, it adds a COIN-D6 LiDAR and a high-resolution LCD screen. The motors are upgraded to Hall magnetic encoder geared motors for more precise motion and steering control.
Core Advantage: Offers the highest hardware integration and feature density in its price range. With the LCD screen, users can control the robot without a PC or mobile app. By simply pressing buttons on the device, they can experience built-in functions such as face tracking, gesture control, body control, and AI conversation. With the LiDAR expansion, users can fully implement SLAM localization and mapping, path planning, and dynamic obstacle avoidance.
3. Key Differences Explained
3.1 DC Motors vs Hall Magnetic Encoder Geared Motors
Standard DC motors are sufficient for basic movement control and stable 360° omnidirectional motion. Hall magnetic encoder geared motors add position feedback capability and support closed-loop control, allowing real-time acquisition of wheel speed and motion status. This results in more precise movement and is an important foundation for stable SLAM mapping and autonomous navigation.
3.2 “AI Vision + Ultrasonic” vs “AI Vision + LiDAR Perception”
Both robot cars can perform AI vision recognition through the camera. TurboPi, paired with ultrasonic sensors, can only achieve one-directional short-range obstacle avoidance. ClawPi supports LiDAR expansion, providing 360° high-precision ranging and mapping capabilities. Vision recognition (“what it is”) and LiDAR ranging (“how far it is”) complement each other, creating a more complete 3D spatial perception that easily supports SLAM navigation and advanced embodied AI tasks.
3.3 Mobile App vs LCD Screen
TurboPi requires a Wi-Fi connection and is controlled via a mobile app. ClawPi supports mobile app control while also featuring a 1.9-inch LCD screen. Face tracking, gesture control, body control, and AI conversation functions are pre-installed on the device. After powering on, users can switch between functions using the onboard buttons without connecting to a mobile app, offering a more convenient interaction experience.
4. Core Parameter Comparison
| Comparison Item | TurboPi | ClawPi |
|---|---|---|
| Controller | Raspberry Pi 5 / 4B | Raspberry Pi 5 |
| Product Dimensions | 197 × 164 × 113 mm | 260 × 207 × 138 mm |
| Motors | High-performance DC motors | Hall magnetic encoder geared motors |
| LiDAR | None | COIN-D6 LiDAR |
| Display Module | None | High-resolution LCD screen (with built-in modes) |
| AI Large Model Deployment | Supported on Deluxe version and above | Supported on all versions |
| Core Advantage | More complete AI vision curriculum and learning path | Integrates LiDAR + screen, supports SLAM mapping & navigation |
| Purchase Recommendation | Beginners whose main goal is learning AI vision algorithms and basic Python programming | Users who want a low-barrier way to learn ROS2 SLAM navigation and prefer convenient interaction |
FAQ
Q1: Which model is easier for beginners with no ROS2 background?
A: Both models are designed for beginners. If you want a gradual and systematic learning path that builds a solid programming foundation, TurboPi’s structured lessons are more friendly. If you prefer a ready-to-play experience right after powering on, choose ClawPi — the screen has multiple built-in application modes.
Q2: When should I prioritize ClawPi?
A: Choose ClawPi if your learning or project involves SLAM mapping, path planning, and autonomous obstacle avoidance, or if you value a convenient “ready-to-play” experience.
Q3: Both models support AI large models and OpenClaw. What’s the difference in application capability?
A: Basic AI functions such as voice interaction and large-model visual understanding offer the same experience. However, ClawPi supports SLAM mapping and navigation, so it can combine large models to complete more advanced tasks such as intelligent navigation-based transport and multi-point navigation transport.
Q4: How do Hall magnetic encoder geared motors improve the robot’s performance?
A: Magnetic encoder motors provide real-time feedback on wheel speed and rotation angle, enabling closed-loop control. This not only improves straight-line stability and turning accuracy, but also significantly reduces cumulative error during path planning.
Q5: Both products include a 2-DOF robotic arm. What’s the difference in usage?
A: Both support visual grasping and similar applications. ClawPi can further combine its navigation capability to achieve more complex tasks such as mobile grasping and designated-area transport.
Q6: Are both products open source? Are they convenient for secondary development?
A: Yes, both are fully open source with strong expandability. The low-level control source code, OpenCV vision algorithms, ROS2 function nodes, and large model APIs are all fully open. Rich interfaces are also reserved, making it easy for developers to modify the source code or add custom functions.