Debugging Procedure for Single Serial Bus Servos with a USB-to-TTL Module
1. Introduction
This tutorial aims to help developers better understand the operating principles of Hiwonder serial bus servos. The application scenarios in this guide are strictly limited to the debugging and testing phases of a single servo and are not recommended for specific deployment environments.
2. Wiring Instructions
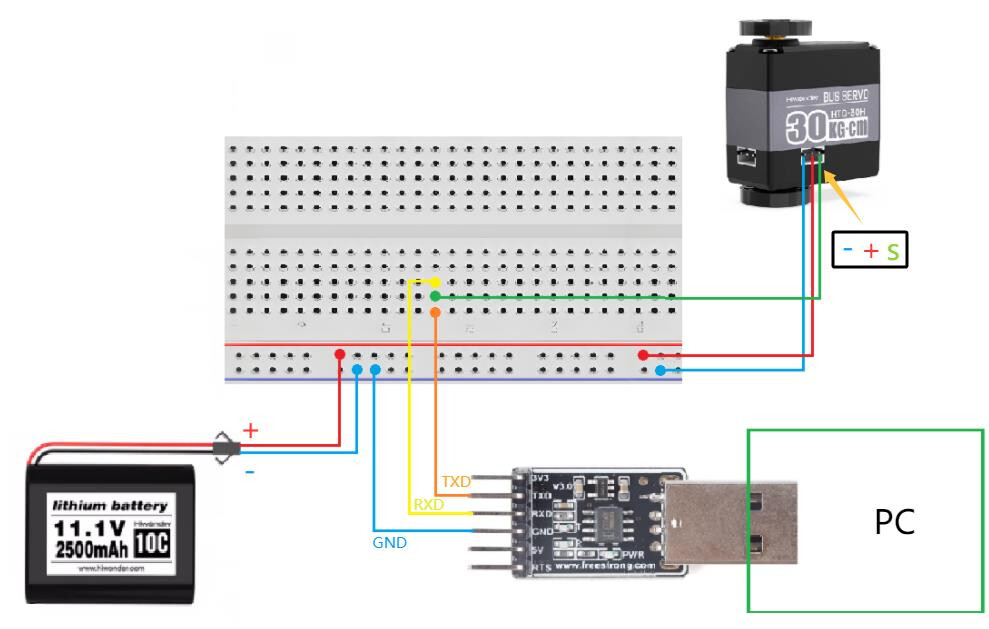
The hardware used in this tutorial includes a Hiwonder high-voltage serial bus servo, an 11.1 V lithium battery, a USB-to-TTL module, a breadboard, and DuPont wires. Hiwonder high-voltage serial bus servos generally utilize an 11.1 V power supply, while low-voltage serial bus servos typically use a 7.4 V power supply. Verification of the match between the operating voltage of the serial bus servo and the power supply voltage is required during actual operation. Utilizing a power supply that matches the operating voltage of the serial bus servo is critical to prevent damage to the component.
The S pin or signal line of the servo must connect in series with both the RXD and TXD pins of the USB-to-TTL module. The negative terminal of the 11.1V lithium battery must connect in series with both the GND pin of the servo and the GND pin of the USB-to-TTL module. The positive pin of the servo connects directly to the positive terminal of the 11.1 V lithium battery. The USB interface of the USB-to-TTL module connects directly to the PC. The specific wiring layout is illustrated in the diagram below.
3. Operational Demonstration
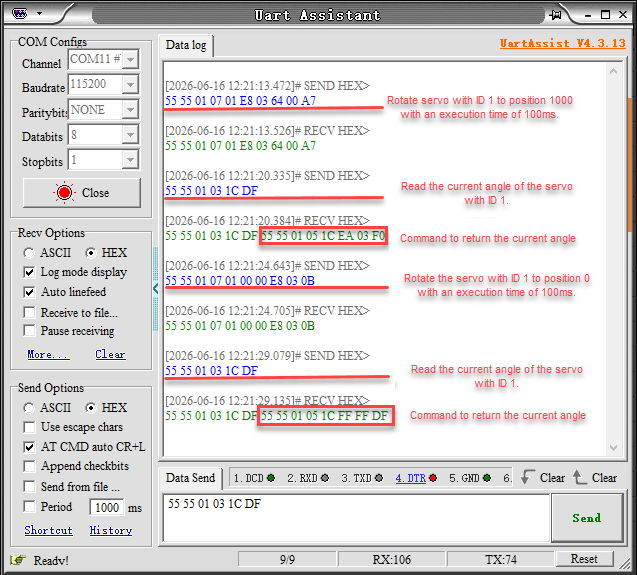
Launch the serial debugging assistant and configure the serial port settings according to the illustration below before transmitting serial commands for control and data retrieval based on the Hiwonder Bus Servo Communication Protocol.
Because the TXD and RXD pins of the USB-to-TTL module are shorted and connected in series with the signal line of the servo, commands transmitted from the serial debugging assistant will automatically echo back through the RXD line during operation, which represents normal behavior.
Specific command examples can be referenced in the diagram below.